Commercial Robotic Mower Setup: What to Prepare Before Deployment
Deploying a commercial robotic mower involves more than selecting a machine with the right cutting capacity. Before autonomous mowing begins, operators need to assess the mowing area, define working boundaries, prepare navigation and mapping, and make sure the charging area and operating conditions are suitable. A clear setup process helps ensure that the mower can operate within the intended area and perform consistently from the start.
01 Assess Your Mowing Area
Before deployment, start by evaluating the property where the mower will operate. The total mowing area is important, but it is not the only factor to consider.
Look at the overall layout, terrain, slopes, trees, paths, fixed structures, narrow passages, and areas that should not be mowed. These conditions can affect how the mower navigates the site and how the working area should be configured.
| Site factor | What to consider |
|---|---|
| Mowing area | Total area and daily mowing requirements |
| Terrain | Slopes, uneven ground and surface conditions |
| Layout | Open areas, narrow passages and separate zones |
| Obstacles | Trees, paths, structures and fixed objects |
| Access | Routes between different mowing areas |
A site assessment provides the basis for the rest of the setup process.
02 Define Mowing Areas and Boundaries
Once the site has been assessed, define where the mower should and should not operate.
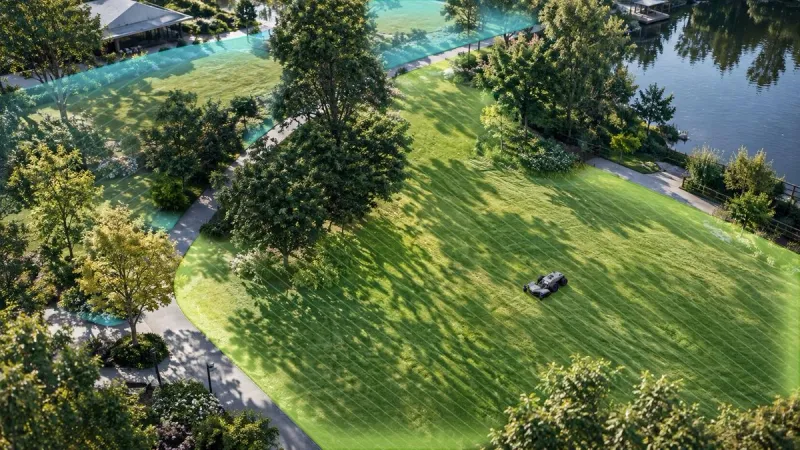
Large commercial properties may include multiple mowing areas, paths, buildings, landscaping features, or other areas that need to remain outside the mowing zone. These areas should be clearly represented in the mower's operating map.
Depending on the navigation system, working areas may be defined through virtual boundaries or other site-specific boundary methods.
Clear boundaries help the mower stay within the intended operating area and make it easier to manage different mowing zones.
03 Set Up Navigation and Mapping
Navigation and mapping are central to autonomous mowing. The setup process should establish how the mower will determine its position and navigate the operating area.
Commercial robotic mowers may use technologies such as RTK positioning, LiDAR, AI Vision, and other sensors to support autonomous navigation.
The initial mapping process typically establishes:
- The mowing area
- Working boundaries
- Restricted areas
- Routes or operating zones
- Relevant site features
For larger or more complex properties, the quality of the initial map can have a direct impact on how effectively the mower operates within the designated area.
This is also where different navigation technologies work together. RTK can provide precise positioning, while LiDAR and AI Vision can contribute environmental information for autonomous navigation.
04 Prepare the Charging Area
The charging area should be considered as part of the overall deployment plan rather than as a separate installation detail.
The location should provide:
- Reliable access for the mower
- Suitable ground conditions
- Access to the required power supply
- Adequate space for the mower to approach and leave the charging station
The charging location should also fit naturally into the mower's operating area so that returning for charging does not create unnecessary access limitations.
For commercial operations with long mowing cycles, charging and runtime should be considered together with the expected mowing requirements.
05 Test the Mower Before Full Operation
Before starting regular autonomous mowing, conduct an initial test of the mapped area.
The test should confirm that:
- The mowing boundaries are correctly defined.
- The mower can navigate the intended operating area.
- Restricted areas are correctly configured.
- The charging area is accessible.
A test run can also reveal site-specific conditions that were not obvious during the initial assessment. The map or operating area can then be adjusted before regular mowing begins.
A successful deployment is therefore not simply about putting the mower on the property. It is about matching the mower's navigation, operating area, and site conditions before autonomous mowing becomes part of the regular maintenance process.